

Collaborative Robot Arm for Injection Molding Machine
Product Introduction
Our company is a professional manufacturer of Mecanum Wheel Module, HUB Motor, Military Patrol Robot. We rely on a young and international design concept, keeping on to the spirit of being responsible to society, customers and enterprises. Over the years, our company has won wide acclaim for our demanding quality and professional service attitude. It is necessary to update the corporate quality management concept at any time and continuously improve the level of technology and quality to survive and develop in the fierce market environment where opportunities and challenges coexist.
Product introduction

1. Product features
1. 1. High degree of automation: the circuit can be designed by the computer or the induction magnetic strip of the magnetic air sensor can guide the passage and automatically charge;
1. 2. The manipulator rotates 360 degrees without dead angle, with high precision control;
1. 3. Stable operation and stable parking;
1. 4. Improve the corporate image: AGV has a futuristic appearance, beautiful appearance, make a silent environment and high observability with lower price;
1. 5. High working efficiency: shorten working hours without manual management, so as to improve enterprise efficiency.
1. 6. You can choose whether to configure the latent AGV or not.
2. Application scenario
Collaborative mobile robots can be used in automatic chemical plants, post offices, warehouses, libraries, docks, airports, mobile robots, warehousing and logistics robots, coffee shops, planting greenhouses and other work platforms to meet the needs of different industries such as warehousing, manufacturing, logistics, agriculture, etc., with a wide range of applications, stable quality and large shipment volume.
3. Parameter

The above parameters are for reference only. Our product technology is constantly updated and upgraded. At the same time, we also accept the customization and development of customers.
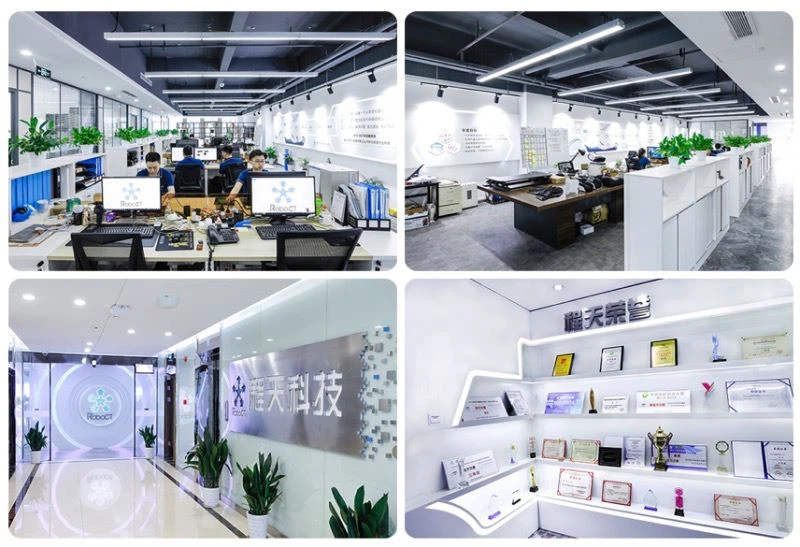
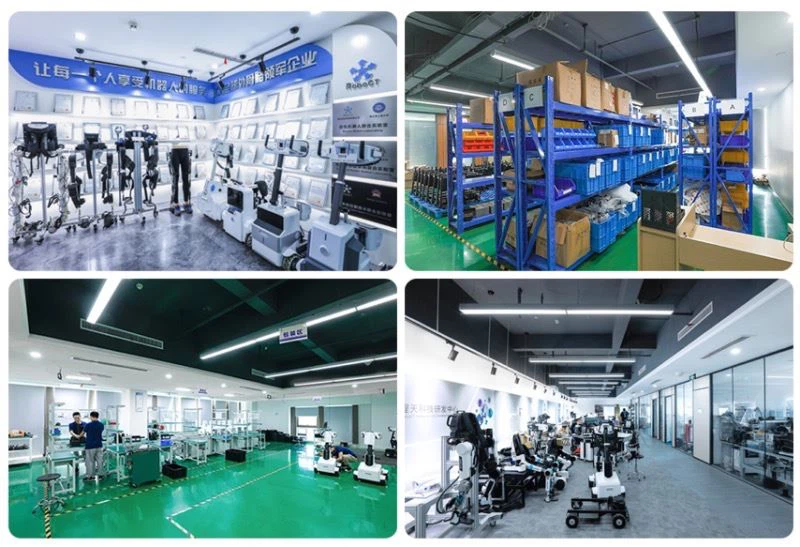
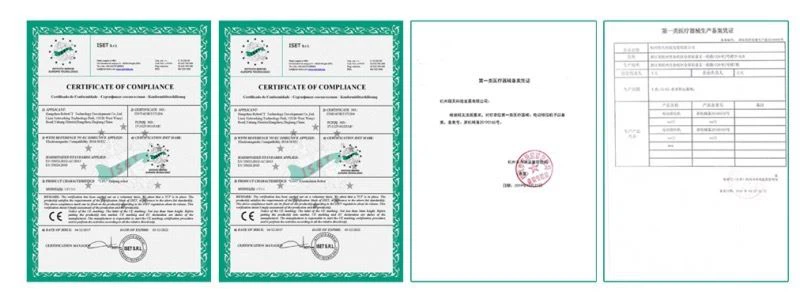
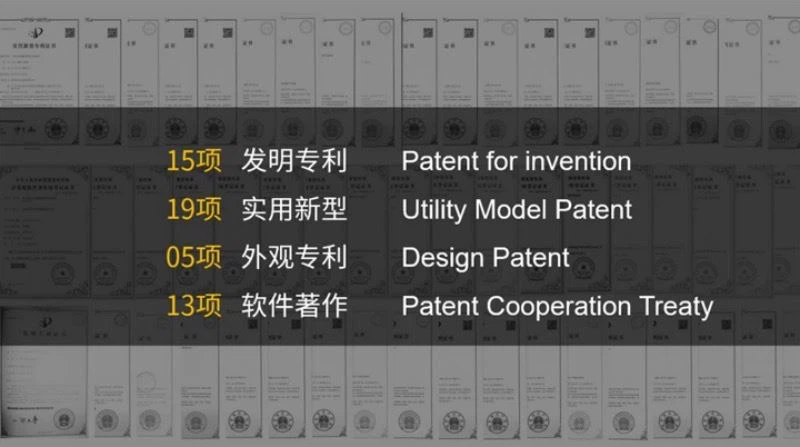
4. Factory and qualification
5. Instructions and precautions
5. 1. Electric shock hazard, this equipment must be connected with the power supply under the condition of protective grounding.
5. 2. Equipment susceptible to magnetic field interference shall not be placed near the collaborative mobile robot, which may cause interference to it.
5. 3. The collaborative mobile robot is limited to driving on flat ground, please keep away from the steps.
5. 4. When the manipulator moves close to the boundary of the motion range, its attitude cannot be specified arbitrarily.
5. 5. In the cylinder space directly above and below the base of the mechanical arm, it is necessary to avoid moving the tool to the cylinder space as much as possible, which will cause a joint to move too fast when the speed of the tool is very slow, thus causing the robot to activate the automatic protection mechanism.
6. Instructions for regular maintenance
(1) The base and arm of industrial manipulator always need to be cleaned regularly. If solvent is used, strong solvent such as acetone should be avoided, and high-pressure cleaning equipment can also be used, but direct injection to manipulator should be avoided. To prevent static electricity, do not use a dry cloth to wipe. Hollow wrist, if necessary, clean as necessary to avoid dust and particles accumulation. Clean with lint free cloth. After cleaning, add a small amount of Vaseline or similar substances to the wrist surface to facilitate future cleaning.
(2) The inspection of industrial manipulator includes the inspection of whether the bolts are loose and slippery; whether the parts easy to loose and hard to separate are normal; whether the speed change is complete; whether the safety protection and safety device of the operating system are flexible and reliable; whether the equipment is corroded, smashed, pulled away and oil leakage, water, electricity, etc.; whether the surrounding ground is clean, tidy and free of oil, debris, etc.; and the inspection of lubrication Add the lubricating oil with fixed quality and quantity at fixed time and fixed point.
(3) The axle brake test of industrial robot is to determine whether the brake works normally, because in the process of operation, each axle motor brake will wear normally, so it must be tested. The test method is as follows:
A. Run the manipulator shaft to the corresponding position, where the total weight and all loads of the manipulator reach the maximum value (maximum static load);
B. Cut off the power of the motor;
C. Check whether all the shafts remain in place. If the manipulator still does not change its position when the motor is powered off, the braking torque is sufficient. The manipulator can also be moved to check whether further protection measures are needed. When the mobile robot stops in an emergency, the brake will help to stop, so wear may occur. Therefore, it is necessary to test repeatedly during the service life of the machine to check whether the machine maintains the original ability.
High quality embodies our dignity and excellent service makes our Collaborative Robot Arm for Injection Molding Machine unimpeded in every corner of the world. Are you still looking for a quality product that is in accordance with your good company image while expanding your product range? Try our quality products. Since the establishment of our company, we have been enterprising and constantly innovating. Our professional team has been growing in the tide of the market and won the market competitiveness with its strong product development and design and production capacity.
Hot Tags: collaborative mobile robot, China, manufacturers, suppliers, wholesale, custom, high quality, Patrol Inspection Robot, Omnidirectional Wheel Module, 5a Current Sensor, High Speed Brushless Dc Motor, 5 Channel Flame Sensor, Linear Absolute Encoder
[[ProKeywords]]SPEC DATA
Send Inquiry